Hardware
2,309 items in 11 lists
-
Ardupilot Copter Checklist ardupilot.org
.
-
Ardupilot ardupilot.org
Full ecosystem including professional / research use for wings and copters and even land or water vehicles. A lot of information, experiences and possibilities, but also more complex than INAV.
-
Agilicious agilicious.dev
3D printed OSHW drone and ecosystem esp. for CV autonomous agile flight research, 2023
-
URDF wiki.ros.org
Examples on how to create Unified Robot Description Format (URDF) for different kinds of robots.
-
tf2 wiki.ros.org
Transform library, which lets the user keep track of multiple coordinate frames over time.
-
rviz stereo wiki.ros.org
3D stereo rendering displays a different view to each eye so that the scene appears to have depth.
-
rqt_graph wiki.ros.org
Provides a GUI plugin for visualizing the ROS computation graph.
-
rqt_bag wiki.ros.org
Provides a GUI plugin for displaying and replaying ROS bag files.
-
rqt wiki.ros.org
A Qt-based framework for GUI development for ROS. It consists of three parts/metapackages.
-
Launch wiki.ros.org
Templates on how to create launch files for larger projects.
-
Roslaunch Nodes in Valgrind or GDB wiki.ros.org
When debugging roscpp nodes that you are launching with roslaunch, you may wish to launch the node in a debugging program like gdb or valgrind instead.
-
dynamic_reconfigure wiki.ros.org
The focus of dynamic_reconfigure is on providing a standard way to expose a subset of a node's parameters to external reconfiguration.
-
UnitTesting wiki.ros.org
This page lays out the rationale, best practices, and policies for writing and running unit tests and integration tests for ROS.
-
Python wiki.ros.org
Style guide to be followed in writing Python code for ROS.
-
ROS IDEs wiki.ros.org
This page collects experience and advice on using integrated development environments (IDEs) with ROS.
-
PREEMPT_RT kernel patch wiki.linuxfoundation.org
Aim of the PREEMPT_RT kernel patch is to minimize the amount of kernel code that is non-preemptible.
-
Xen wiki.debian.org
An open-source (GPL) type-1 or baremetal hypervisor.
-
Pressed wiki.debian.org
Provides a way to set answers to questions asked during the installation process of debian, without having to manually enter the answers while the installation is running.
-
UTD19 utd19.ethz.ch
Largest multi-city traffic dataset publically available.
-
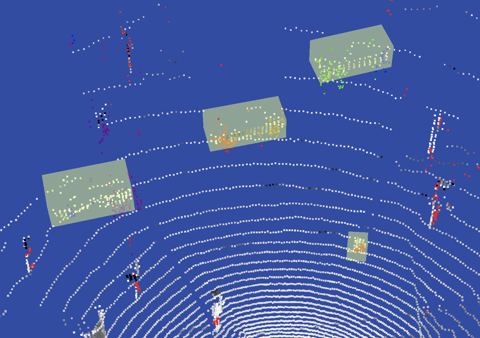
h3d usa.honda-ri.com
The H3D is a large scale full-surround 3D multi-object detection and tracking dataset from Honda.
-
undraw undraw.co
Free Professional business SVGs easy to customize.
-
TensorFlow Datasets tensorflow.org
TensorFlow Datasets provides many public datasets as tf.data.Datasets.
-
swiftlatex swiftlatex.com
A WYSIWYG Browser-based LaTeX Editor.
-
SVGrepo svgrepo.com
Download free SVG Vectors for commercial use.
-
simulation assets for the SubT subtchallenge.world
This collection contains simulation assets for the SubT Challenge Virtual Competition in Gazebo.
-
Lyft Level 5 Dataset self-driving.lyft.com
Level 5 is developing a self-driving system for the Lyft network. We're collecting and processing data from our autonomous fleet and sharing it with you.
-
ryo-iso ryo-iso.readthedocs.io
A modern ISO builder that streamlines the process of deploying a complete robot operating system from a yaml config file.
-
Ruckig ruckig.com
Instantaneous Motion Generation. Real-time. Jerk-constrained. Time-optimal.
-
rosbuild roscon.ros.org
The ROS build farm.
-
robmosys robmosys.eu
RobMoSys envisions an integrated approach built on top of the current code-centric robotic platforms, by applying model-driven methods and tools.
-
riscv riscv.org
The Free and Open RISC Instruction Set Architecture.
-
inspect pymotw.com
The inspect module provides functions for learning about live objects, including modules, classes, instances, functions, and methods.
-
ASTYX HIRES2019 DATASET pinchofintelligence.com
Automotive Radar Dataset for Deep Learning Based 3D Object Detection.
-
Papers With Code paperswithcode.com
Thousands of machine learning datasets provided by Papers With Code.
-
PandaPower pandapower.org
An easy to use open source tool for power system modeling, analysis and optimization with a high degree of automation.
-
opensourcedesign opensourcedesign.net
Community and Resources for Free Design and Logo Creation.
-
OpenDRIVE opendrive.org
An open file format for the logical description of road networks.
-
opencrg opencrg.org
Open file formats and open source tools for the detailed description, creation and evaluation of road surfaces.
-
ONCE dataset once-for-auto-driving.github.io
A large-scale autonomous driving dataset with 2D&3D object annotations.
-
netplan netplan.io
Simply create a YAML description of the required network interfaces and what each should be configured to do.
-
ROSOnWindows ms-iot.github.io
An experimental release of ROS1 for Windows.
-
moveit moveit.ros.org
Easy-to-use robotics manipulation platform for developing applications, evaluating designs, and building integrated products.
-
micro-ros micro-ros.github.io
The major changes compared to "regular" ROS 2 is that micro-ROS uses a Real-Time Operating System (RTOS) instead of Linux, and DDS for eXtremely Resource Constrained Environments.
-
Mapillary Vistas Dataset mapillary.com
A diverse street-level imagery dataset with pixel‑accurate and instance‑specific human annotations for understanding street scenes around the world.
-
lttng lttng.org
An open source software toolkit which you can use to simultaneously trace the Linux kernel, user applications, and user libraries.
-
terminator launchpad.net
The goal of this project is to produce a useful tool for arranging terminals.
-
OpenVX khronos.org
Enables performance and power-optimized computer vision processing, especially important in embedded and real-time use cases.
-
Ignition Robotics ignitionrobotics.org
Test control strategies in safety, and take advantage of simulation in continuous integration tests.
-
gpu-voxels gpu-voxels.org
GPU-Voxels is a CUDA based library which allows high resolution volumetric collision detection between animated 3D models and live pointclouds from 3D sensors of all kinds.
-
Kitware SLAM gitlab.kitware.com
LiDAR-only visual SLAM developped by Kitware, as well as ROS and ParaView wrappings for easier use.
- next page of items loading…