-
Luminar luminartech.com
LIDAR manufacturer focusing on compact, auto-grade sensors. Luminar is headquartered Palo Alto, California, USA.
-
GitHub repository ltriess.github.io
-
LSLIDAR lslidar.com
LSLiDAR (Leishen Intelligent System Co., Ltd.) is a LIDAR sensor manufacturer and complete solution provider based in Shenzhen, China.
-
Livox livoxtech.com
LIDAR manufacturer.
-
Paper link.springer.com
libpointmatcher: Comparing ICP variants on real-world data sets.
-
LGSVL / SVL lgsvlsimulator.com
Unity Engine based simulator for automotive applications. Compatible with Autoware, Baidu Apollo and ROS/ROS 2. Note: LG has made the difficult decision to suspend active development of SVL Simulator.
-
Lyft level5.lyft.com
Public dataset collected by a fleet of Ford Fusion vehicles equipped with LIDAR and camera.
-
Study of LIDAR Semantic Segmentation larissa.triess.eu
Scan-based Semantic Segmentation of LiDAR Point Clouds: An Experimental Study IV 2020.
-
direct_visual_lidar_calibration koide3.github.io
General, Single-shot, Target-less, and Automatic LiDAR-Camera Extrinsic Calibration Toolbox
-
Kaolin kaolin.readthedocs.io
Kaolin is a PyTorch Library for Accelerating 3D Deep Learning Research written by NVIDIA Technologies for game and application developers.
-
Paper joss.theoj.org
-
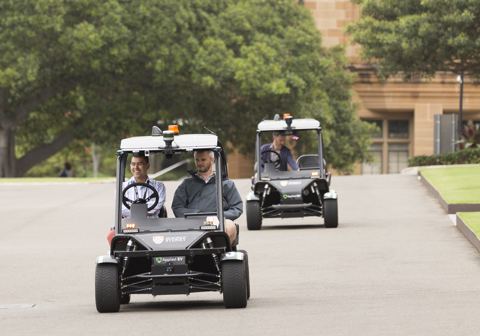
USyd Dataset- The Univerisity of Sydney Campus- Dataset its.acfr.usyd.edu.au
Long-term, large-scale dataset collected over the period of 1.5 years on a weekly basis over the University of Sydney campus and surrounds. It includes multiple sensor modalities and covers various environmental conditions. ROS compatible
-
RangeNet++ ipb.uni-bonn.de
Fast and Accurate LiDAR Sematnic Segmentation with fully convolutional network.
-
KISS-SLAM ipb.uni-bonn.de
KISS-SLAM is a simple, robust, and accurate 3D LiDAR SLAM system that just works.
-
OverlapNet ipb.uni-bonn.de
Loop Closing for LiDAR-based SLAM.
-
SuMa++ ipb.uni-bonn.de
LiDAR-based Semantic SLAM.
-
LIDAR-MOS ipb.uni-bonn.de
Moving Object Segmentation in 3D LIDAR Data
-
Innoviz innoviz.tech
Innoviz technologies / specializes in solid-state LIDARs.
-
MOLA ingmec.ual.es
Modular system for Localization and Mapping, providing LiDAR Odometry (LO), LiDAR-inertial Odometry (LIO), SLAM, localization-only modes, and geo-referencing.
-
Paper ieeexplore.ieee.org
-
Paper ieeexplore.ieee.org
-
ALFA Framework ieeexplore.ieee.org
An open-source framework for developing processing algorithms, with a focus on embedded platforms and hardware acceleration.
-
LineFit Graph ieeexplore.ieee.org
Line fitting-based fast ground segmentation for horizontal 3D LiDAR data
-
Ibeo ibeo-as.com
Ibeo Automotive Systems GmbH is an automotive industry / environmental detection laserscanner / LIDAR manufacturer, based in Hamburg, Germany.
-
Hokuyo hokuyo-aut.jp
Sensor and automation manufacturer, headquartered in Osaka, Japan.
-
Hesai hesaitech.com
Hesai Technology is a LIDAR manufacturer, founded in Shanghai, China.
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
Lichtblick suite github.com
Lichtblick is an open-source alternative to Foxglove Studio for visualizing and analyzing robotics data.
-
GitHub repository github.com
-
GitHub organization github.com
-
GitHub repository github.com
-
GitHub organization github.com
-
GitHub organization github.com
-
OSRF Gazebo gazebosim.org
OGRE-based general-purpose robotic simulator, ROS/ROS 2 compatible.
-
Foxglove foxglove.dev
Foxglove Studio is an integrated visualization and diagnosis tool for robotics, available in your browser or for download as a desktop app on Linux, Windows, and macOS.
-
EU Long-term Dataset epan-utbm.github.io
This dataset was collected with our robocar (in human driving mode of course), equipped up to eleven heterogeneous sensors, in the downtown (for long-term data) and a suburb (for roundabout data) of Montbéliard in France. The vehicle speed was limited to 50 km/h following the…
-
urban_road_filter doi.org
Real-Time LIDAR-Based Urban Road and Sidewalk Detection for Autonomous Vehicles
-
ROS 2 docs.ros.org
compatible
-
Cirrus dataset developer.volvocars.com
A public datatset from non-uniform distribution of LIDAR scanning patterns with emphasis on long range. In this dataset Luminar Hydra LIDAR is used. The dataset is available at the Volvo Cars Innovation Portal.
-
KITTI cvlibs.net
Widespread public dataset, pirmarily focusing on computer vision applications, but also contains LIDAR point cloud.
-
CoppeliaSim coppeliarobotics.com
Cross-platform general-purpose robotic simulator (formerly known as V-REP).
-
CloudCompare cloudcompare.org
CloudCompare is a free, cross-platform point cloud editor software.
- next page of items loading…