LOAM J. Zhang and S. Singh
LOAM: Lidar Odometry and Mapping in Real-time.
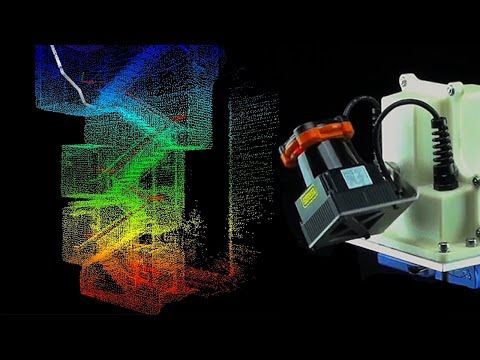
- from
- LIDAR
- added
- 2026-10-10
- likes
- 0
similar
-
loam_velodyne github.com
Laser Odometry and Mapping (Loam) is a realtime method for state estimation and mapping using a 3D lidar.
-
M-LOAM github.com
Robust Odometry and Mapping for Multi-LiDAR Systems with Online Extrinsic Calibration.
-
-
LeGO-LOAM github.com
A lightweight and ground optimized lidar odometry and mapping (LeGO-LOAM) system for ROS compatible UGVs.
-
-
lio-mapping github.com
Implementation of Tightly Coupled 3D Lidar Inertial Odometry and Mapping (LIO-mapping).
LIDAR › Algorithms > Simultaneous localization and mapping SLAM and LIDAR-based odometry and or mapping LOAM: “LOAM: Lidar Odometry and Mapping in Real-time.”