LIO-SAM
Tightly-coupled Lidar Inertial Odometry via Smoothing and Mapping.
- from
- LIDAR
- added
- 2026-10-10
- likes
- 0
similar
-
lio-mapping github.com
Implementation of Tightly Coupled 3D Lidar Inertial Odometry and Mapping (LIO-mapping).
-
-
-
-
-
FAST-LIO2 arxiv.org
Fast LiDAR-Inertial Odometry is a computationally efficient and robust LiDAR-inertial odometry package
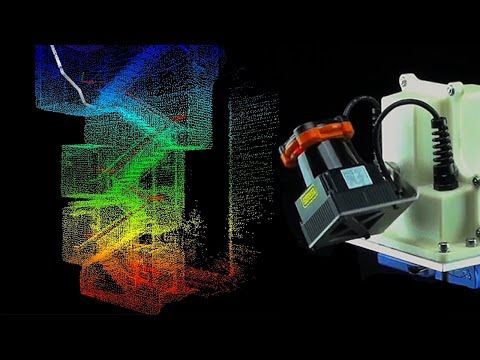
LIDAR › Algorithms > Simultaneous localization and mapping SLAM and LIDAR-based odometry and or mapping LOAM: “Tightly-coupled Lidar Inertial Odometry via Smoothing and Mapping.”