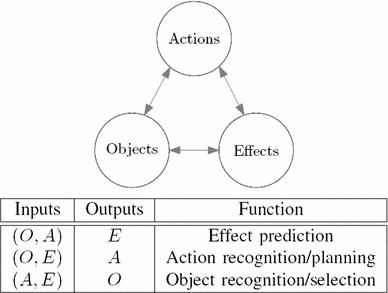
A Relational Approach to Tool-Use Learning in Robots
ILP'12, 2012. [All Versions].
- from
- AGI & CoCoSci
- added
- 2026-10-10
- likes
- 0
similar
-
-
Relational affordances for multiple-object manipulation link.springer.com
Autonomous Robots, 2017. [All Versions].
-
Learning Efficient Logical Robot Strategies Involving Composable Objects andrewcropper.com
IJCAI'15, 2015. [All Versions].
-
Differentiable Physics and Stable Modes for Tool-Use and Manipulation Planning dspace.mit.edu
Robotics: Science and Systems, 2018. [All Versions].
-
Towards combining inductive logic programming with Bayesian networks link.springer.com
ILP'01, 2001. [All Versions].
-
Handbook of Knowledge Representation 1lib.net
Elsevier, 2008. [All Versions]. A pragmatical handbook for all kinds of knowledge representation modes.
AGI & CoCoSci › Papers > Embodied Intelligence: “ILP'12, 2012. [All Versions].”