Differentiable Physics and Stable Modes for Tool-Use and Manipulation Planning
Robotics: Science and Systems, 2018. [All Versions].
- from
- AGI & CoCoSci
- added
- 2026-10-10
- likes
- 0
similar
-
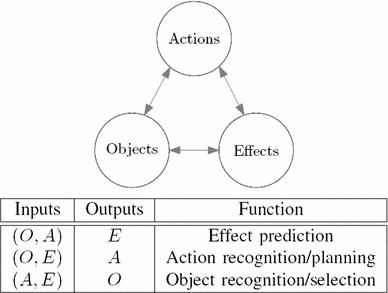
A Relational Approach to Tool-Use Learning in Robots link.springer.com
ILP'12, 2012. [All Versions].
-
A Mathematical Introduction to Robotic Manipulation cds.caltech.edu
-
Relational affordances for multiple-object manipulation link.springer.com
Autonomous Robots, 2017. [All Versions].
-
Data-Efficient Learning for Complex and Real-Time Physical Problem Solving Using Augmented Simulation ieeexplore.ieee.org
Robotics and Automation Letters, 2021. [All Versions].
-
-
Modern Robotics: Mechanics, Planning, and Control coursera.org
AGI & CoCoSci › Papers > Problem Solving > Planning: “Robotics: Science and Systems, 2018. [All Versions].”